NVIDIA-ISAAC-ROS/isaac_ros_pose_estimation
FoundationPose lands in ROS 2, flanked by two classics
This repository gives ROS 2 robots three GPU-accelerated ways to stop guessing where objects are.
Collecting fresh signals — velocity needs a few days of history.
collecting data…
star history
What it does
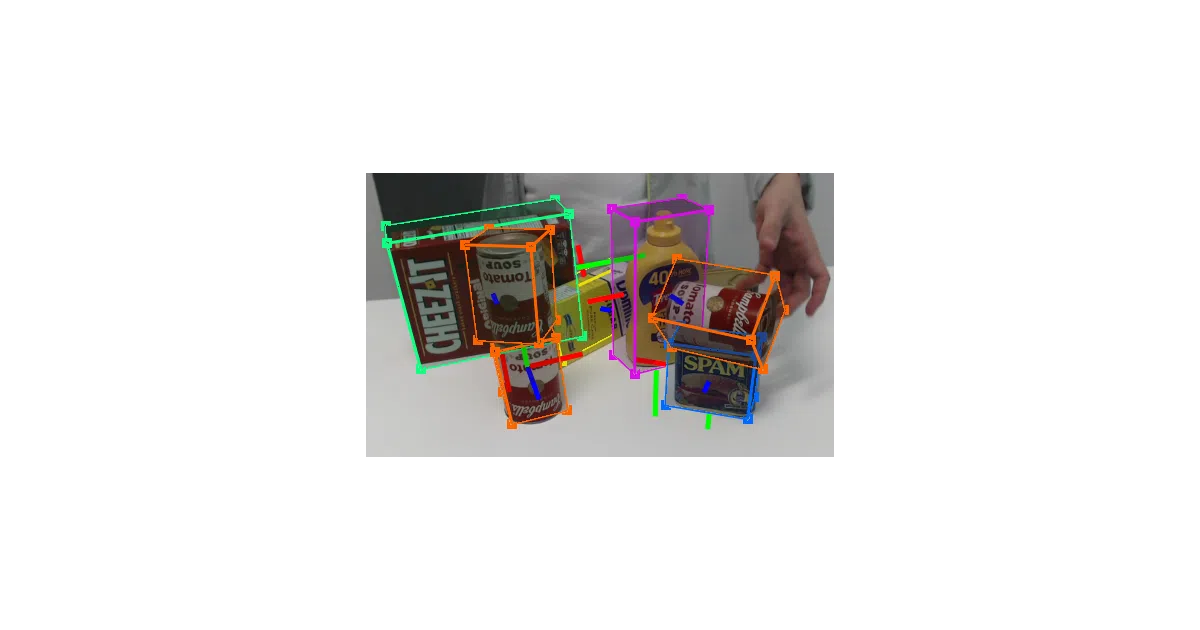
Isaac ROS Pose Estimation provides three ROS 2 nodes that run DNN inference on NVIDIA hardware to predict the 6-DoF pose of objects. The output is meant to be fused with depth data for 3D pose and distance calculations, feeding into navigation or manipulation pipelines. It acts as a hardware-accelerated bridge between computer vision models and robotic perception.
The interesting bit
The package refuses a one-size-fits-all approach. isaac_ros_foundationpose handles novel objects without retraining by refining and scoring pose hypotheses, while isaac_ros_centerpose works at the class level and isaac_ros_dope sticks to specific known instances. Because pose estimation is too heavy to run at camera frame rate, the system is designed to sample poses strategically rather than greedily.
Key highlights
isaac_ros_foundationposeestimates and tracks poses of unseen objects using a refine-and-score model pair; tracking exceeds 120 FPS on Jetson Thor, while 720p pose estimation runs slower (e.g., ~2.4 FPS on AGX Thor T5000).isaac_ros_centerposedetects objects, generates 2D keypoints, and regresses relative 3D cuboid dimensions at the class level, hitting 50.2 FPS on Thor and Orin with VGA input.isaac_ros_dopeis the fastest time-tested option for known objects, though it requires a pre-trained model and retraining for new items.- All three rely on Isaac ROS DNN Inference for TensorRT or Triton acceleration and include an image encoder for preprocessing.
- Benchmarks cover a wide hardware range from Jetson Orin Nano to x86_64 with RTX 5090.
Caveats
- FoundationPose pose estimation is computationally expensive: the 720p node drops below 1 FPS on AGX Orin and reaches only ~5 FPS on an RTX 5090.
- DOPE requires training your own model for objects outside the provided HOPE dataset; it cannot generalize to novel instances.
- CenterPose estimates pose only “up to a scale,” meaning absolute metric scale may need additional handling.
Verdict
Robotics developers already running ROS 2 on NVIDIA hardware should look here for drop-in pose estimation. Everyone else—especially those without a GPU-accelerated Isaac ROS stack—should keep scrolling.
Frequently asked
- What is NVIDIA-ISAAC-ROS/isaac_ros_pose_estimation?
- This repository gives ROS 2 robots three GPU-accelerated ways to stop guessing where objects are.
- Is isaac_ros_pose_estimation open source?
- Yes — NVIDIA-ISAAC-ROS/isaac_ros_pose_estimation is open source, released under the Apache-2.0 license.
- What language is isaac_ros_pose_estimation written in?
- NVIDIA-ISAAC-ROS/isaac_ros_pose_estimation is primarily written in C++.
- How popular is isaac_ros_pose_estimation?
- NVIDIA-ISAAC-ROS/isaac_ros_pose_estimation has 502 stars on GitHub.
- Where can I find isaac_ros_pose_estimation?
- NVIDIA-ISAAC-ROS/isaac_ros_pose_estimation is on GitHub at https://github.com/NVIDIA-ISAAC-ROS/isaac_ros_pose_estimation.