Motphys/UniLab
Robot RL that stops begging for GPU time
A training framework that lets CPU physics simulators feed GPU policy learners through shared memory, so you can train on hardware you actually own.
Not currently ranked — collecting fresh signals.
star history
What it does
UniLab is a reinforcement-learning training stack for robotics that deliberately splits work across heterogeneous hardware. Physics simulation runs on CPU (via MuJoCo or MotrixSim), then streams experience through a shared-memory replay buffer to GPU policy training (PPO, SAC, TD3, APPO, and others). The project explicitly targets setups that aren’t NVIDIA-only: Linux ROCm, Intel XPU, and Apple Silicon are all tracked as first-class setup paths.
The interesting bit
The architecture inverts the typical GPU-everything assumption in RL. By keeping physics on CPU and using unified shared memory as the coupling layer, UniLab lets you train on a MacBook or an AMD box without pretending the simulator can run on your graphics card. The task=<task>/<backend> Hydra config pattern makes switching between MuJoCo and MotrixSim a one-token change.
Key highlights
- Supports MuJoCoUni and MotrixSim backends through adapter-based integration
- Policy algorithms include PPO, MLX PPO, APPO, SAC, TD3, FlashSAC, with HORA and HIM-PPO as script-level workflows
- Cross-platform setup tracked for Linux CUDA, ROCm, XPU, and macOS / Apple Silicon
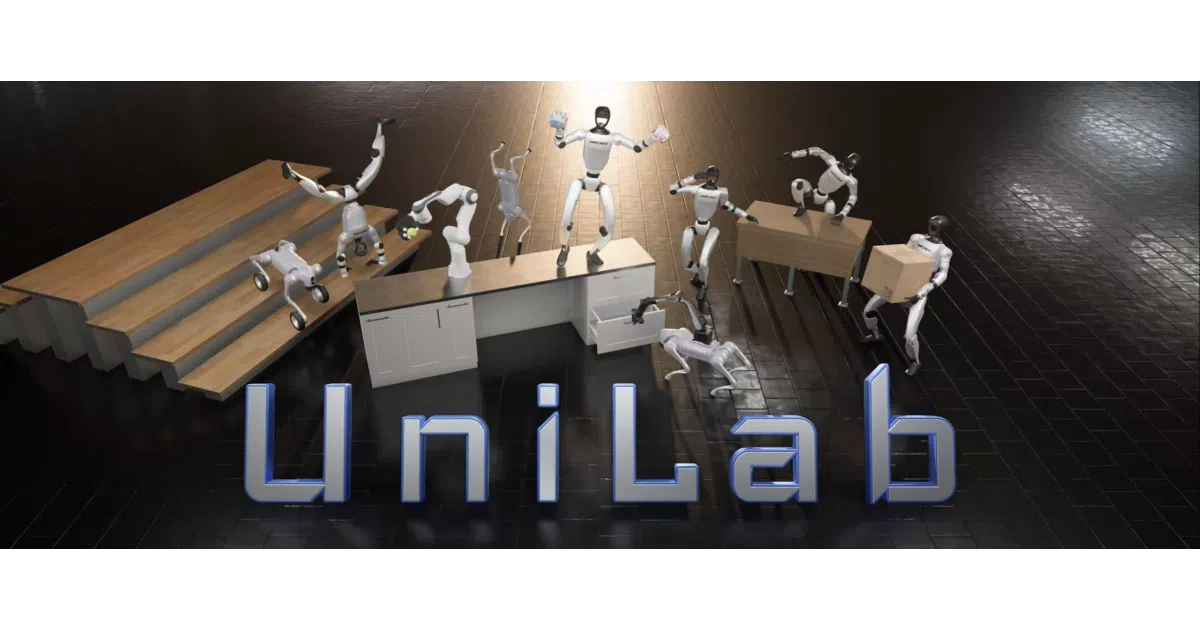
- Pre-trained demo checkpoints (dance, wallflip, in-hand grasp, loco-manipulation) auto-download from Hugging Face
- Hydra-based “task owner” configs bundle task, reward, backend, and algorithm selection in one YAML file
Caveats
- The README notes that Conda and pip users “should still follow the
uvworkflow for now,” so dependency management is effectively uv-mandated - Grasp caches and demo assets pull from Hugging Face on first run; mainland China users need to redirect to a mirror (
hf-mirror.com) - Some algorithm paths (HORA, HIM-PPO) are documented as script-level workflows rather than first-class CLI commands
Verdict
Worth a look if you’re doing robot RL on non-NVIDIA hardware or want to decouple your physics engine from your accelerator budget. Probably overkill if you’re already all-in on CUDA and Isaac Gym.
Frequently asked
- What is Motphys/UniLab?
- A training framework that lets CPU physics simulators feed GPU policy learners through shared memory, so you can train on hardware you actually own.
- Is UniLab open source?
- Yes — Motphys/UniLab is open source, released under the Apache-2.0 license.
- What language is UniLab written in?
- Motphys/UniLab is primarily written in Python.
- How popular is UniLab?
- Motphys/UniLab has 969 stars on GitHub.
- Where can I find UniLab?
- Motphys/UniLab is on GitHub at https://github.com/Motphys/UniLab.