Source-Robotics/PAROL6-Desktop-robot-arm
A robot arm built from filament and industrial ambition
It open-sources the hardware and software for a 3D-printed desktop arm that mimics industrial robot design and control.
Not currently ranked — collecting fresh signals.
star history
What it does
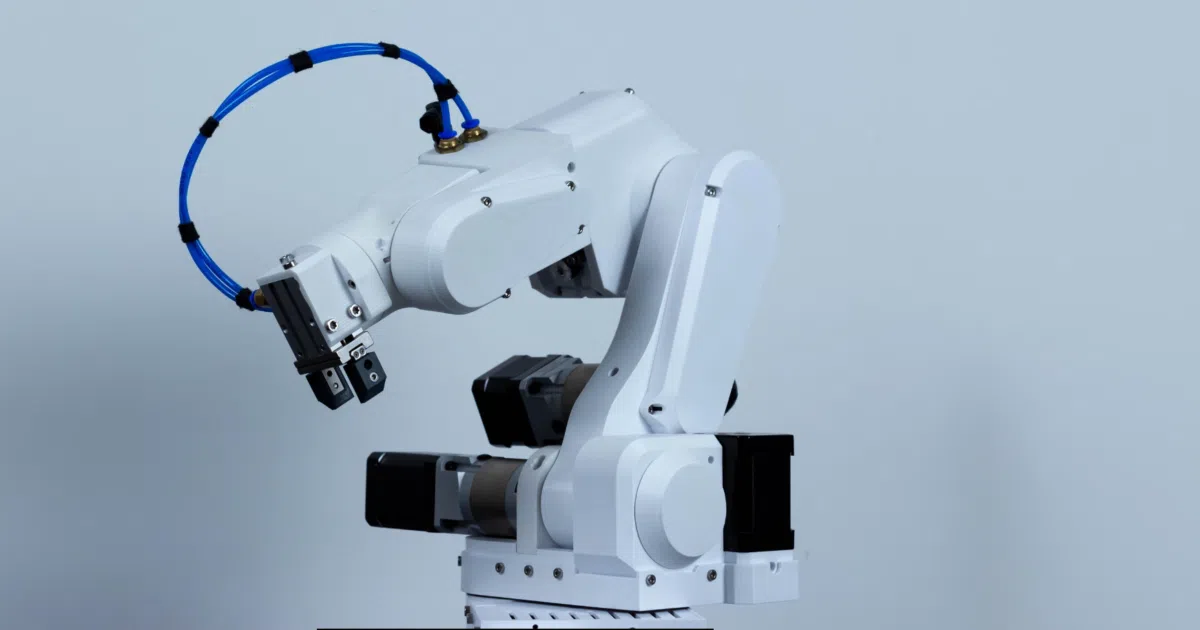
PAROL6 is a desktop robotic arm project that ships open-source STL files, a GUI, and control software under GPLv3. The repository contains the printable mechanical parts, a full BOM, and build instructions for anyone who wants to self-source and assemble the hardware rather than buying pre-built. The stated goal is to echo industrial robot arms in mechanical design, control patterns, and usability.
The interesting bit
While most printable robot arms settle for hobby-servo kinematics, PAROL6 aims for industrial-style motion and software architecture. The ecosystem has already accumulated community projects that layer on LLM-driven vision control, web-based command interfaces, and computer-vision games like tic-tac-toe.
Key highlights
- Open-source STL files, control software, GUI, Python API, and ROS2/MoveIt simulation
- Design philosophy explicitly targets industrial robot mechanics and usability patterns
- Active community extensions including Gemini LLM vision control and web commanders
- Supported by a published BOM with full build instructions; pre-built units also available
- Kinematics and simulation leverage the Python Robotics Toolbox
Caveats
- The README carries an unusually blunt safety warning: the hardware involves lethal voltages and serious hazards, and the authors disclaim all liability for injury or damage.
- Software, hardware designs, and docs are explicitly labeled experimental, incomplete, and potentially buggy.
Verdict
A solid candidate if you want a hackable, industrial-flavored robot arm for research or desktop experimentation. Look elsewhere if you need a finished consumer appliance or guaranteed safety compliance.
Frequently asked
- What is Source-Robotics/PAROL6-Desktop-robot-arm?
- It open-sources the hardware and software for a 3D-printed desktop arm that mimics industrial robot design and control.
- Is PAROL6-Desktop-robot-arm open source?
- Yes — Source-Robotics/PAROL6-Desktop-robot-arm is open source, released under the GPL-3.0 license.
- What language is PAROL6-Desktop-robot-arm written in?
- Source-Robotics/PAROL6-Desktop-robot-arm is primarily written in HTML.
- How popular is PAROL6-Desktop-robot-arm?
- Source-Robotics/PAROL6-Desktop-robot-arm has 3.2k stars on GitHub.
- Where can I find PAROL6-Desktop-robot-arm?
- Source-Robotics/PAROL6-Desktop-robot-arm is on GitHub at https://github.com/Source-Robotics/PAROL6-Desktop-robot-arm.